Machine Learning for robotics and automation
Robot Training
Robot Training. Your task. A robot that learns it.
We train robotic arms, manipulators, humanoids and mobile systems for concrete tasks. Machine Learning, hardware integration and field testing come together, from the first prototype to deployment.
- Real tasks
- Hardware integration
- Field validation
We define the activity, the object and the result the robot needs to achieve.
We develop learning and refine behaviour through testing.
We connect the model to the robot and test the activity’s execution.
We check the result against the real use case and support deployment.
Learning starts with the task
We define the activity the robot needs to perform and develop training around the intended result.
AI and hardware work together
We connect models and robotic platforms, taking account of the environment the system will operate in.
Testing guides the move into operation
From proof of concept to validation, we check behaviour against the real use case before deployment.
AI that acts in the physical world
From movement to doing a job.
Picking an object, assisting a production line or performing an inspection: each activity needs training tied to the robot, environment and objective. We build that connection, from the model to operational testing.
Pick and place and manipulation
Training for grasping, moving and positioning tasks on industrial arms, manipulators and humanoids. We start with the objects and the work to be done.
Line assistance and inspection
We develop robotic applications for manufacturing, production line support and inspection, integrating AI with the platform and process.
Humanoids and mobile systems
Training for agreed tasks and service scenarios. We assess the platform, interactions and operating conditions to develop tailored applications.
Training for the task
Where learning becomes action.
Manipulation and pick and place show the connection between AI training, the robotic platform and the activity to perform.
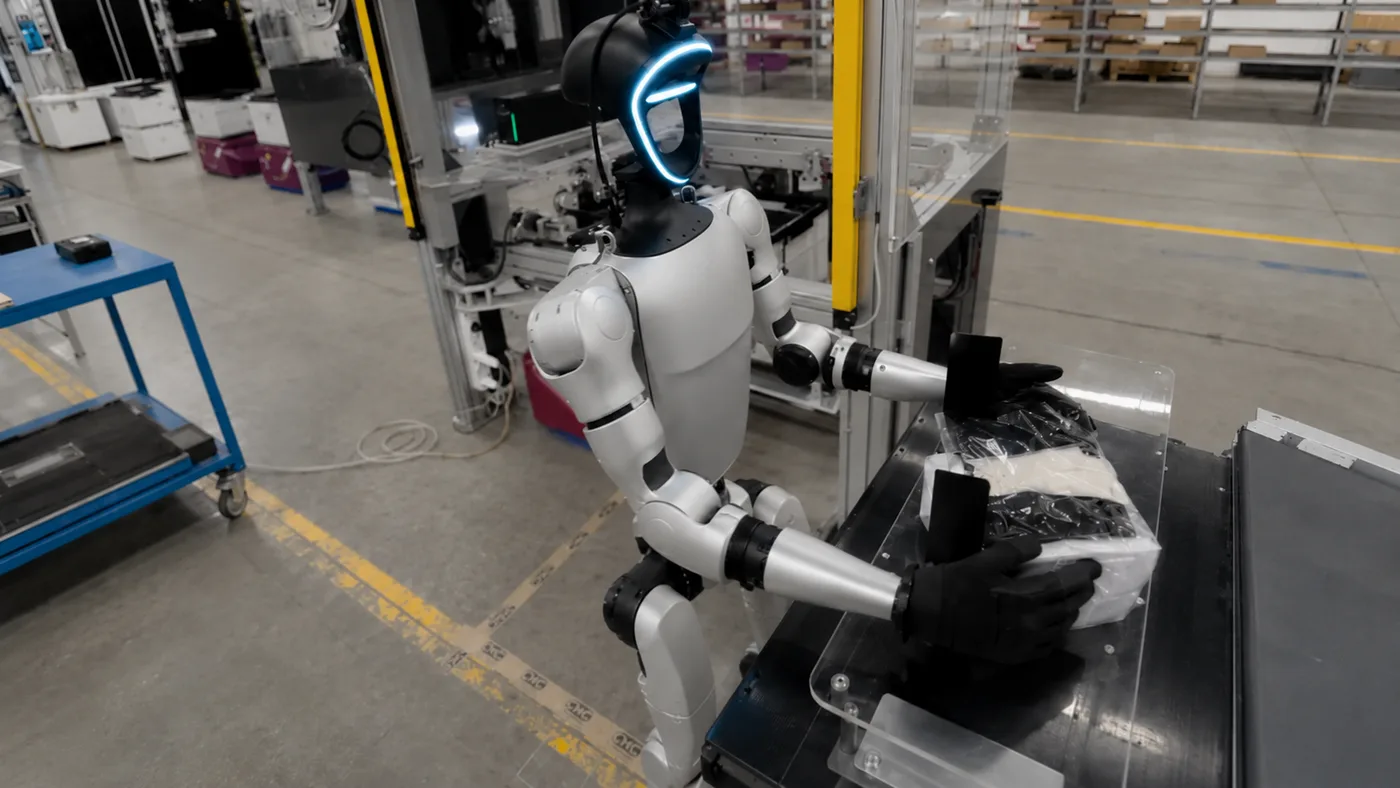
Robot training for manipulation and pick & place tasks
Inside the solution
Models, robots and processes. One project.
A tailored path for training a robotic system to perform a concrete activity.
Machine Learning training
Training development for real tasks, with defined objectives and iterative tests. We design the approach around the robot, available information and intended result.
Industrial arms and manipulators
Training and integration for manipulation, pick and place and line assistance. We consider the hardware platform, task and manufacturing context together.
Humanoids and mobile platforms
Projects on humanoid robots and mobile systems for tailored applications and service scenarios. We define the behaviour to learn and the integration and validation process.
Automation and inspection
Manufacturing applications, line support and inspection: we connect AI to the activities the robot needs to perform within your process.
Proof of concept, validation and deployment
From the initial feasibility assessment to prototyping, hardware integration and field tests. We support deployment and work alongside the project during commissioning.
From task to deployment
Training combines testing and integration.
First, we define what the robot needs to do. Then we develop, test and bring the system into its operating environment.
Define the task
We assess the activity, robotic platform, environment and criteria for checking the result.
Develop the proof of concept
We set up ML training and a prototype to test the approach against the use case.
Integrate and validate
We connect models and hardware and test the system on the task under the intended operating conditions.
Support deployment
We support commissioning and integration into the process, working alongside your team on the project.
Before we begin
The answers you need.
Which robots can you work with?
Industrial arms, manipulators, humanoids and mobile platforms. We start with the available platform or intended task and assess the project’s integration requirements.
Which activities can we address?
Pick and place, manipulation, line assistance, inspection and tailored service scenarios. The project defines the specific task, environment and criteria for checking the result.
Do we need to have chosen a robot already?
You can start with the task you want the system to perform. The initial assessment covers the platform, feasibility and required hardware integration.
How does training lead to work in the field?
Through proof of concept, integration and validation against the real use case. Testing checks behaviour against the agreed task and prepares the system for deployment.
Do you also handle integration and commissioning?
Yes. We combine Machine Learning, hardware integration and field validation, with support through to deployment. We define scope, phases and assistance around your project.
Your next step
What task should your robot learn?
Tell us about the activity, operating environment and platform you have available. We will build a path for training, integration and validation from there.
Discuss your robotics projectStart with the task, even if the robotics project is still taking shape.